The operating challenge
Buildings, vegetation and interrupted connectivity can affect GNSS positioning. A robot needs an application-level response to degraded positioning; an RTK correction source cannot establish operational safety on its own.
 RTKGO
Request a quote ↗
Give compatible robot receivers access to a known GNSS reference source. Validate the reference, network and receiver behavior together with the robot's localization and control system.
For: Robotics manufacturers, outdoor automation integrators and fleet deployment teams
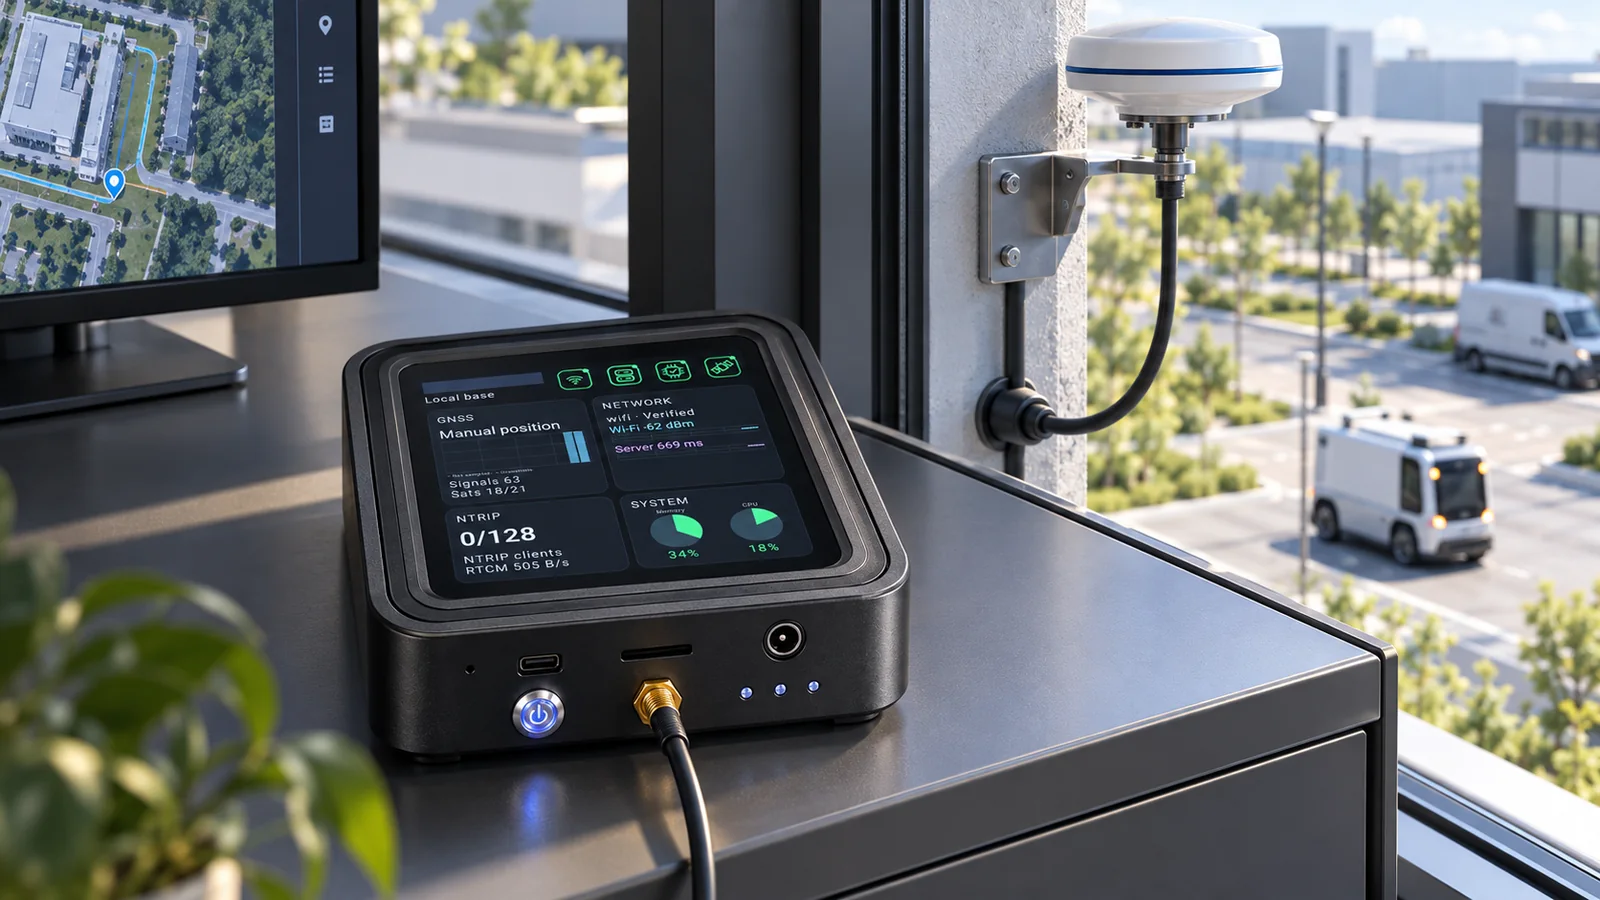
A robotics team evaluates outdoor operations around a landscaped campus. A fixed outdoor antenna and indoor GB30 provide a correction source for compatible robot receivers. The team tests representative routes, shaded areas, network interruptions and recovery before accepting the positioning input for the intended task.
Buildings, vegetation and interrupted connectivity can affect GNSS positioning. A robot needs an application-level response to degraded positioning; an RTK correction source cannot establish operational safety on its own.
Use the GB30 complete kit as fixed reference infrastructure. Connect a compatible robot-side RTK receiver through the selected correction path. HUGEROCK tablets can support commissioning or operational review when the software fits; choose a vehicle terminal only when its integration requirements match the robot platform.
Agree the receiver messages, quality indicators, expected timing and how the application combines GNSS with other sensors.
Include open sky, buildings, vegetation and expected network transition points in the acceptance route.
Test correction interruptions and degraded GNSS conditions using the robot supplier's controlled acceptance procedure.
Record the validated operating conditions and the localization or control system's required response outside them.
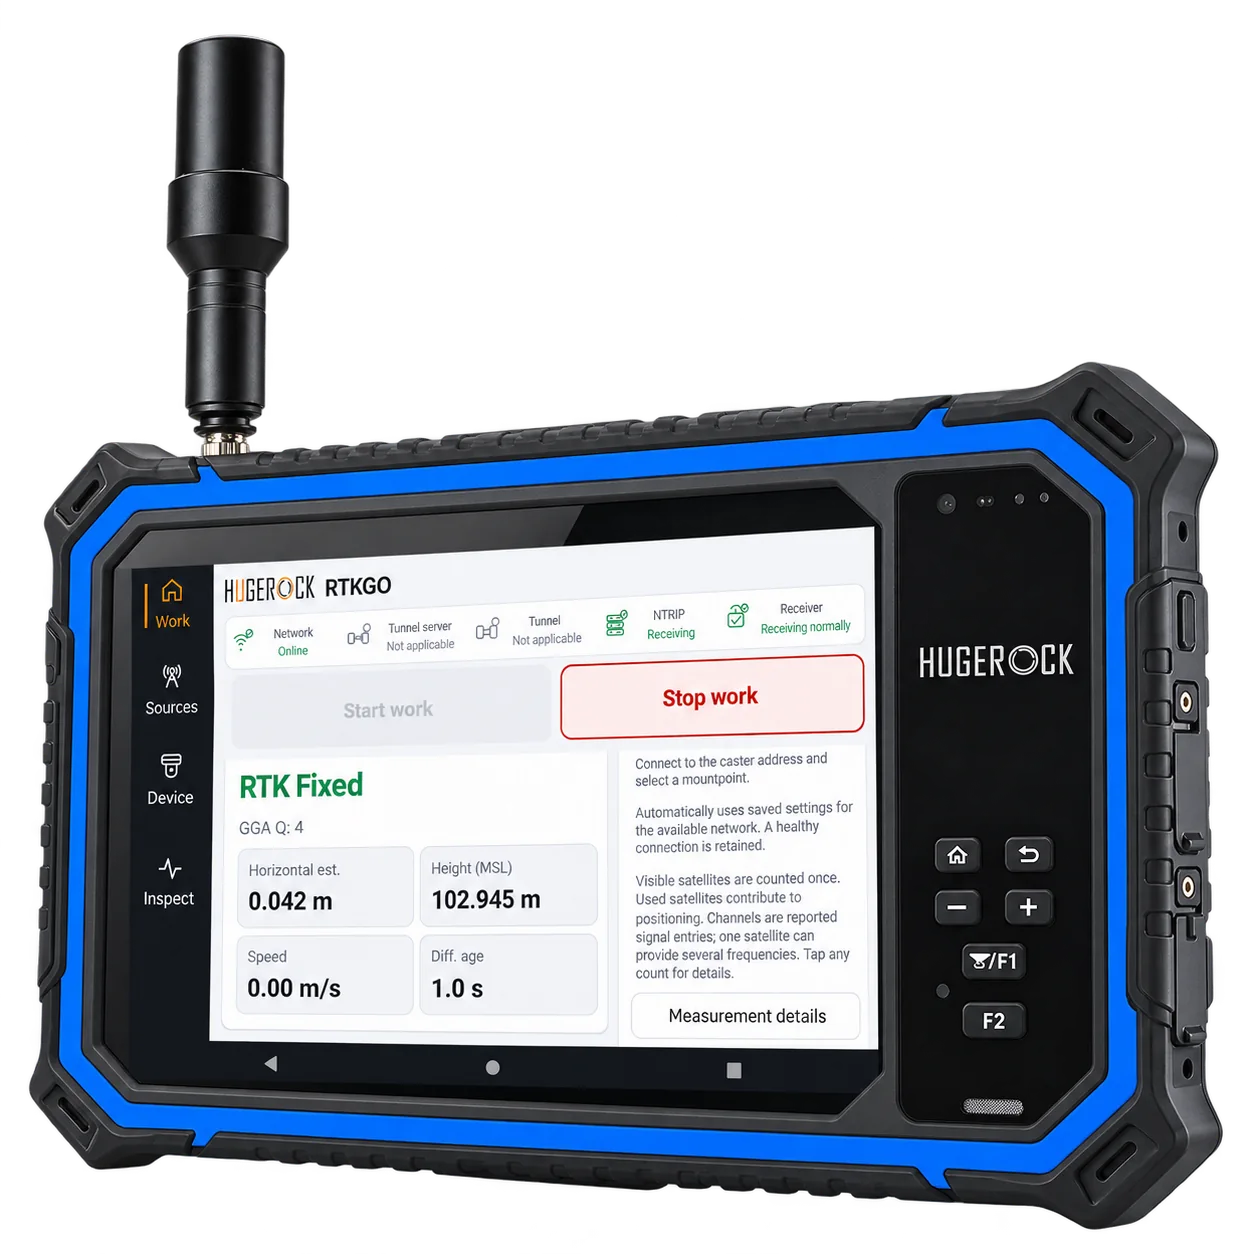
Landscape RTK field tablet
Review specifications →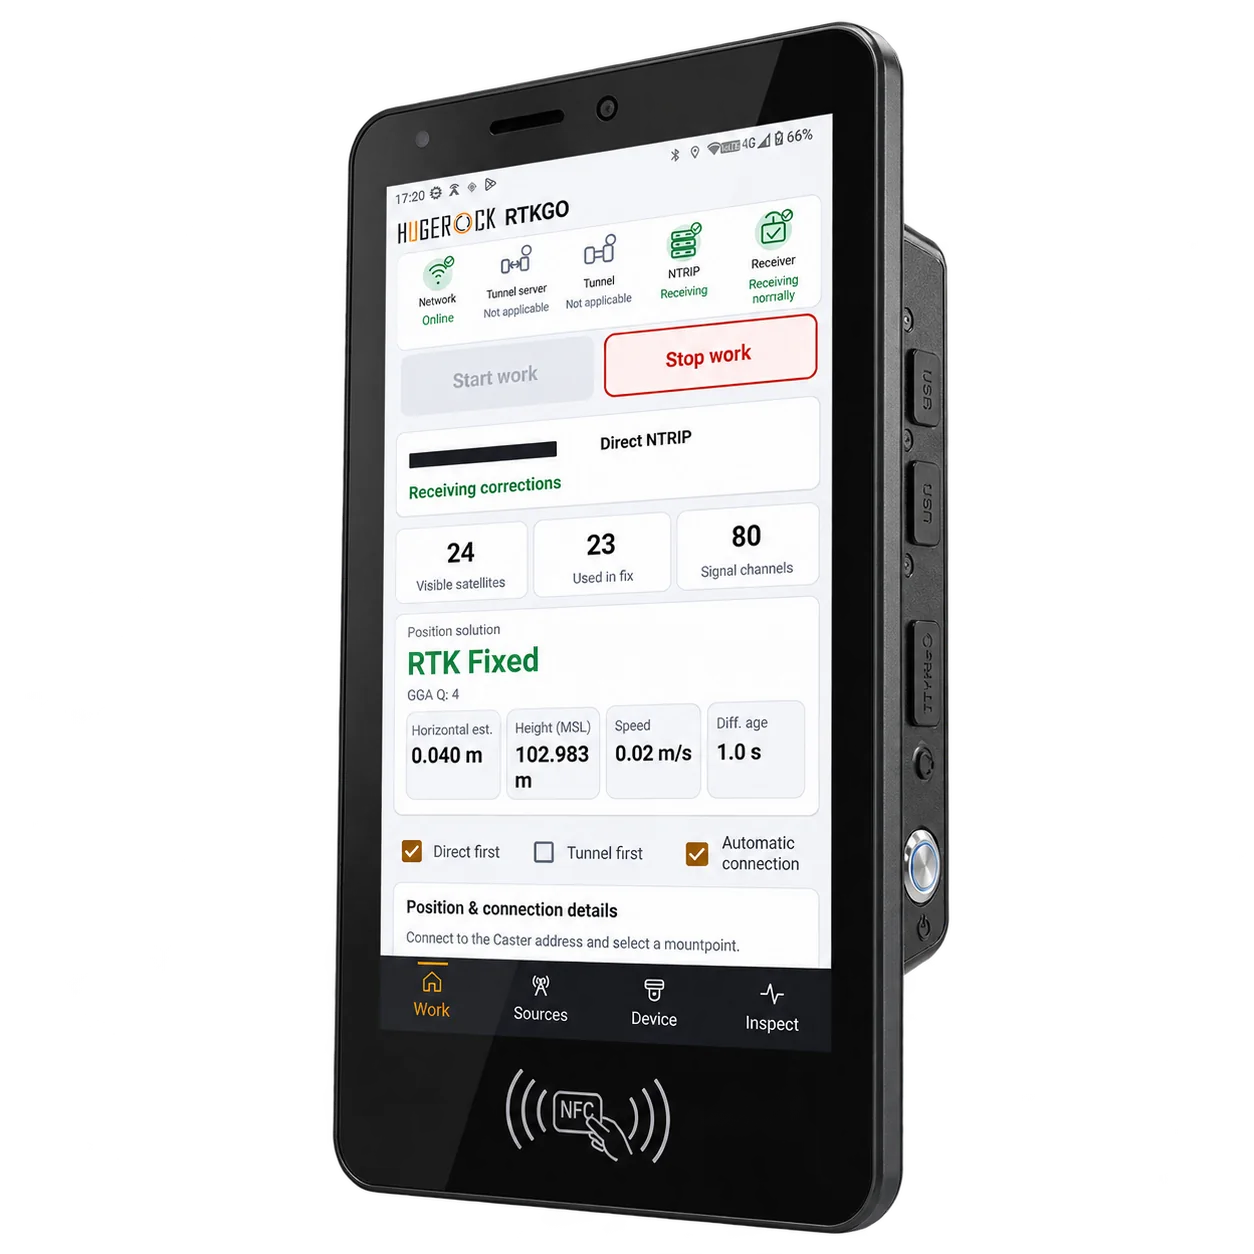
Vehicle-mounted RTK terminal
Review specifications →Confirm the shipping configuration, field application, receiver access and installation requirements. Robot-side and machine-side receivers may be separate industry equipment.
No. GB30 supplies GNSS reference correction infrastructure. Localization, sensor fusion, route planning, control and operational safety belong to the robot system.
A compatible mower receiver may use an appropriate reference correction source. Validate the receiver format, client path, operating area and mower supplier's integration requirements before deployment.
No. Obstructions and operating conditions can degrade GNSS. The robot application must evaluate positioning quality and use the localization and safety approach appropriate to the task.
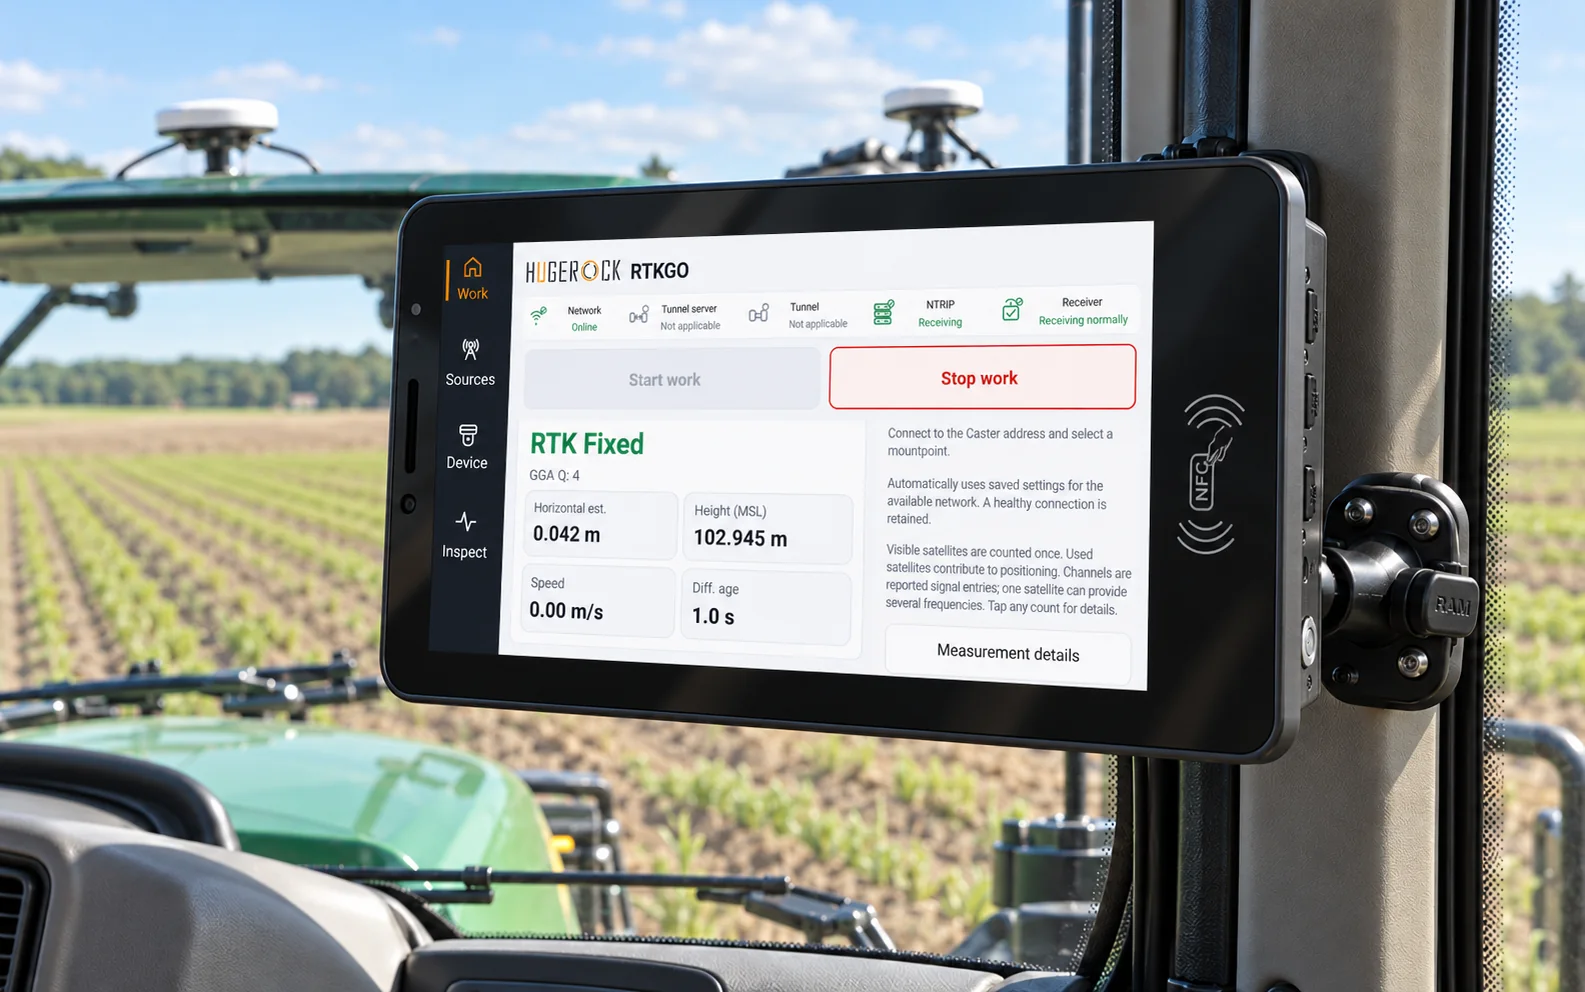
Combine an appropriate reference source with a vehicle terminal, antenna arrangement and host interface. Treat power, positioning, heading and application behavior as one integration review.
Explore this solution →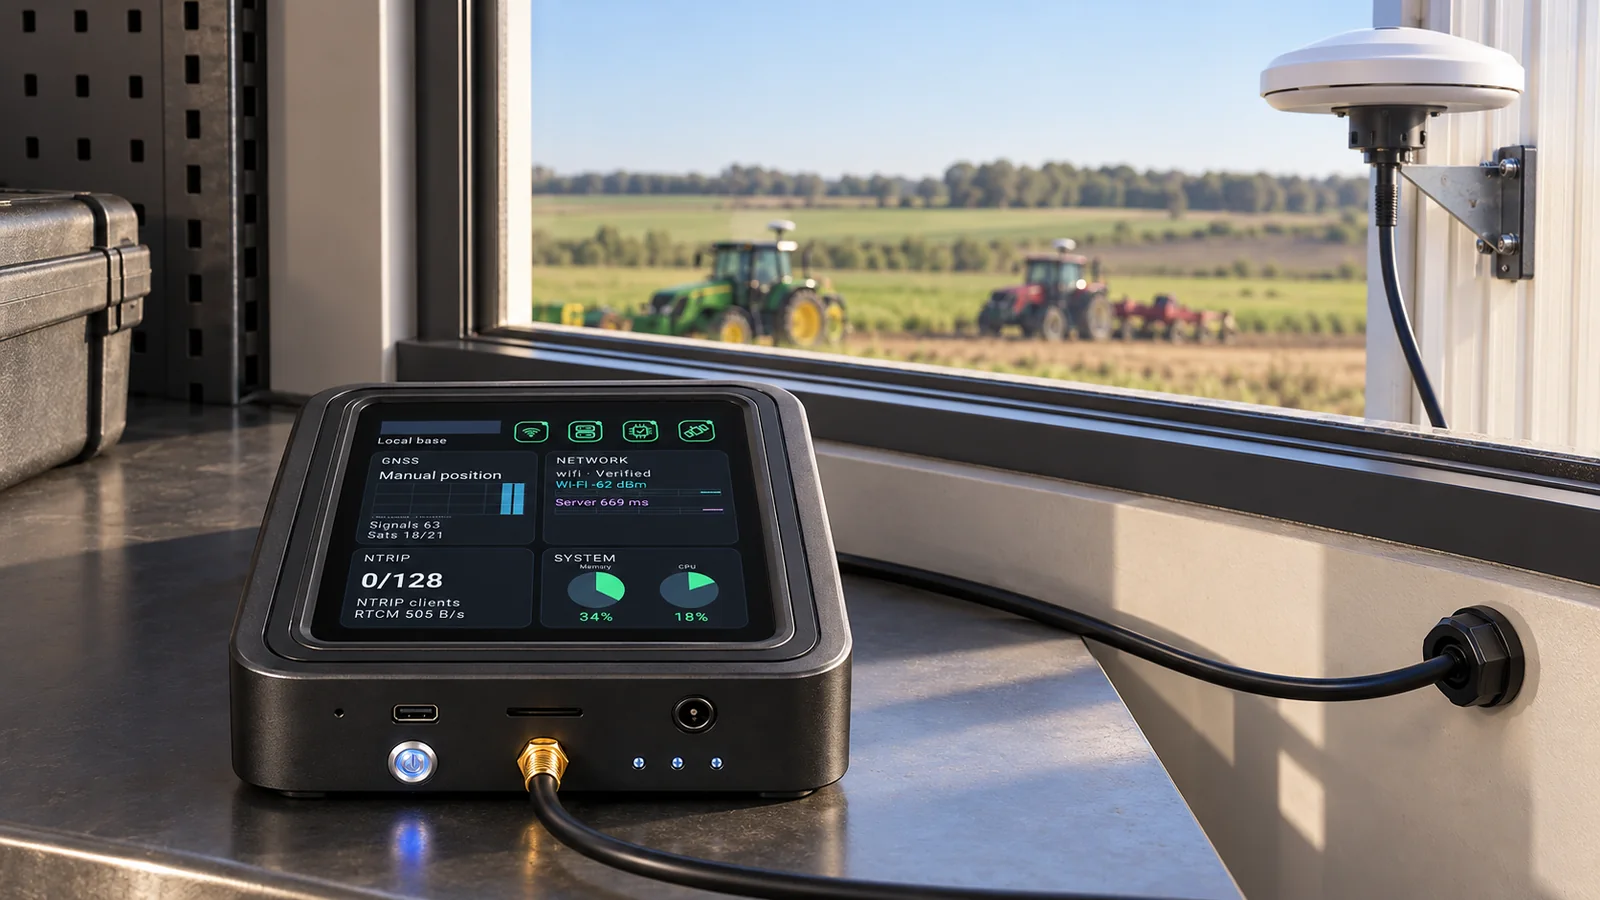
Build the reference layer for a compatible agricultural positioning system. Keep the base installation fixed and evaluate machine terminals, antennas, power and application integration together.
Explore this solution →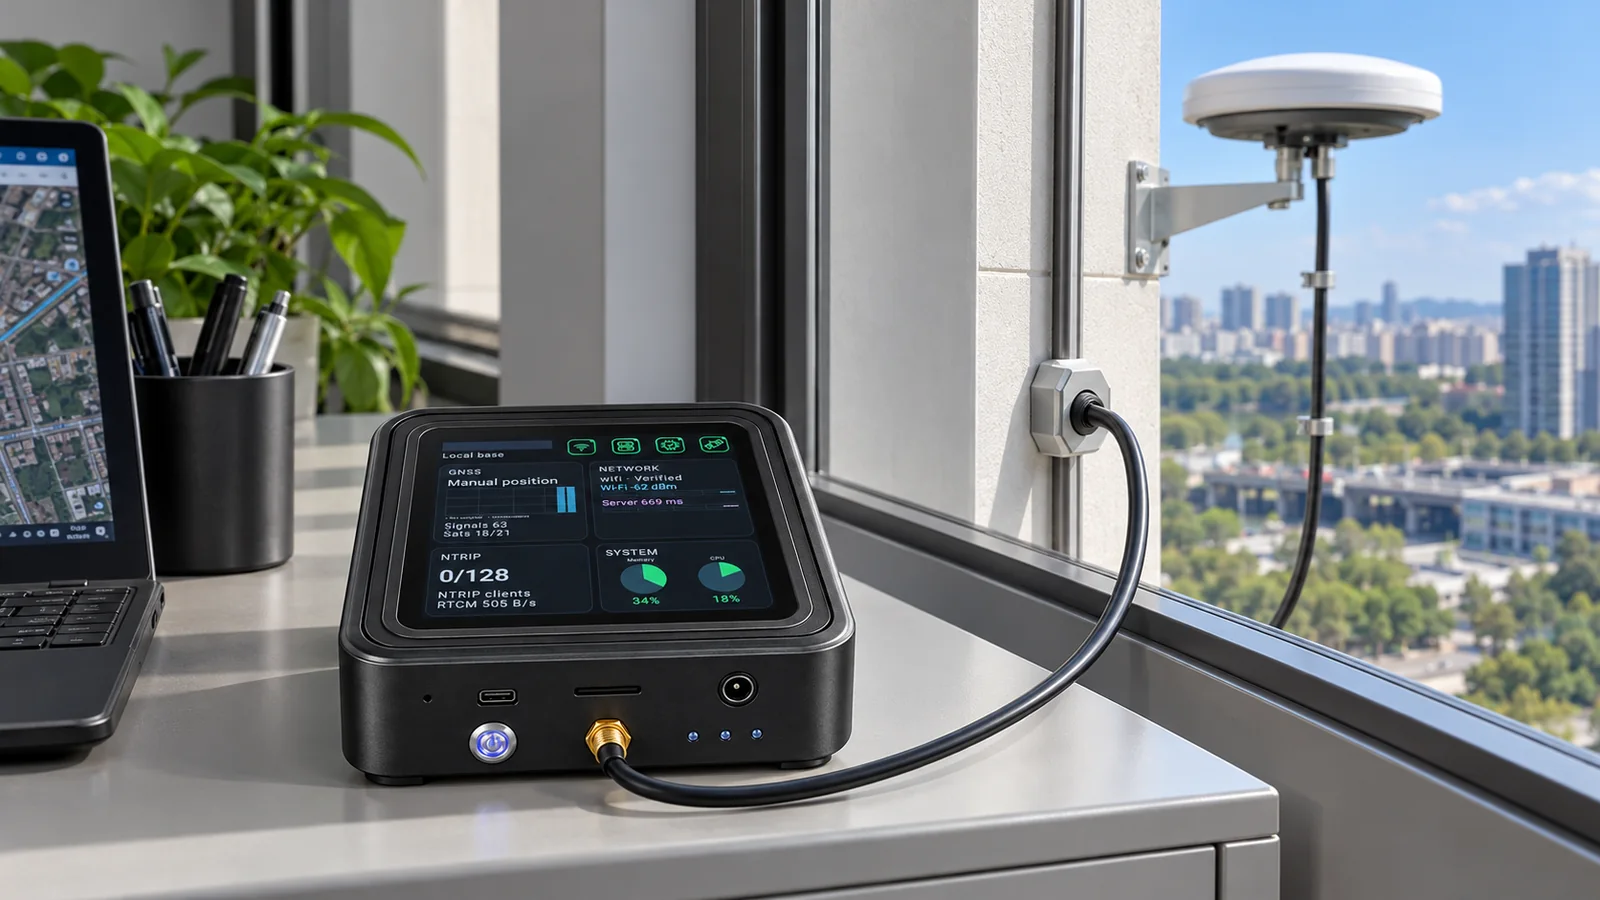
Connect multiple fixed reference points to a central GB30 in Local Base Station mode. Serve its own local source and independent uplink sources through the integrated NTRIP Caster.
Explore this solution →